Overview
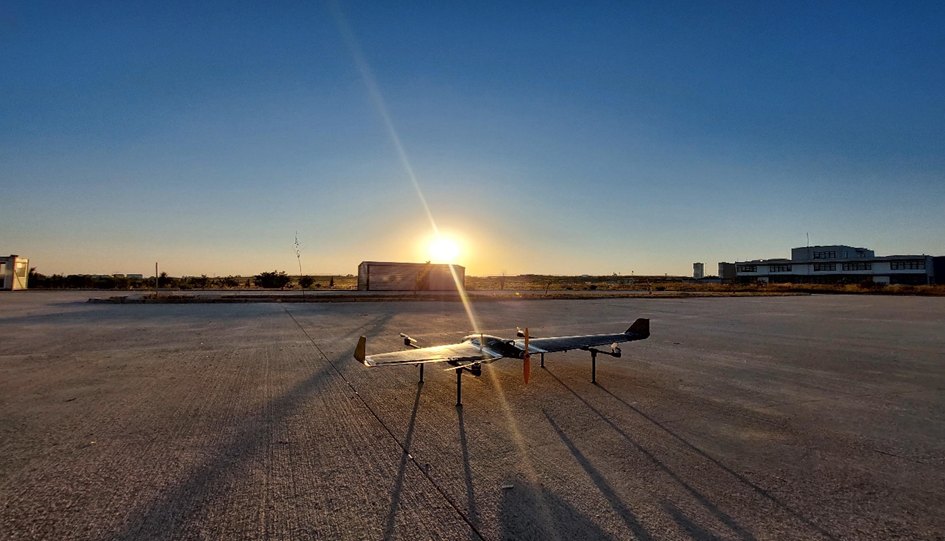
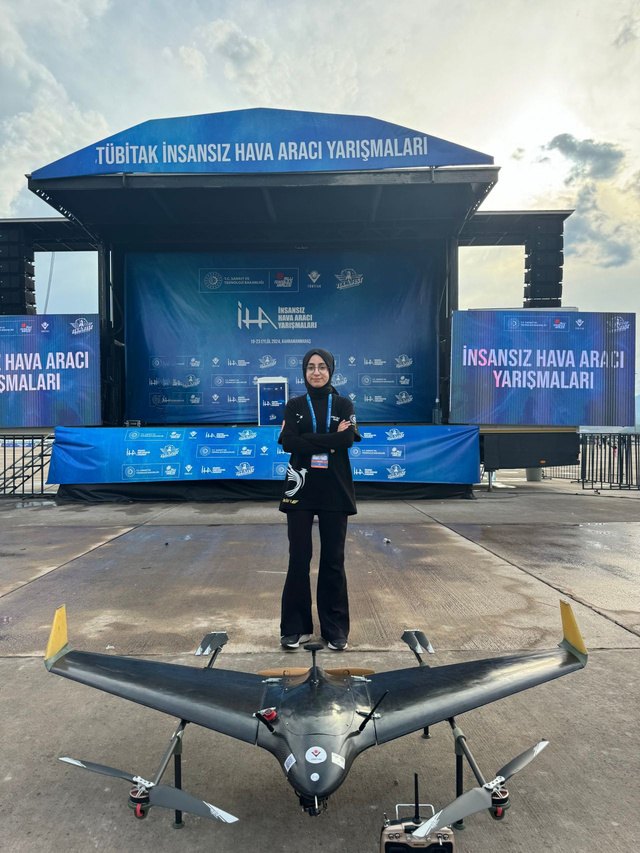
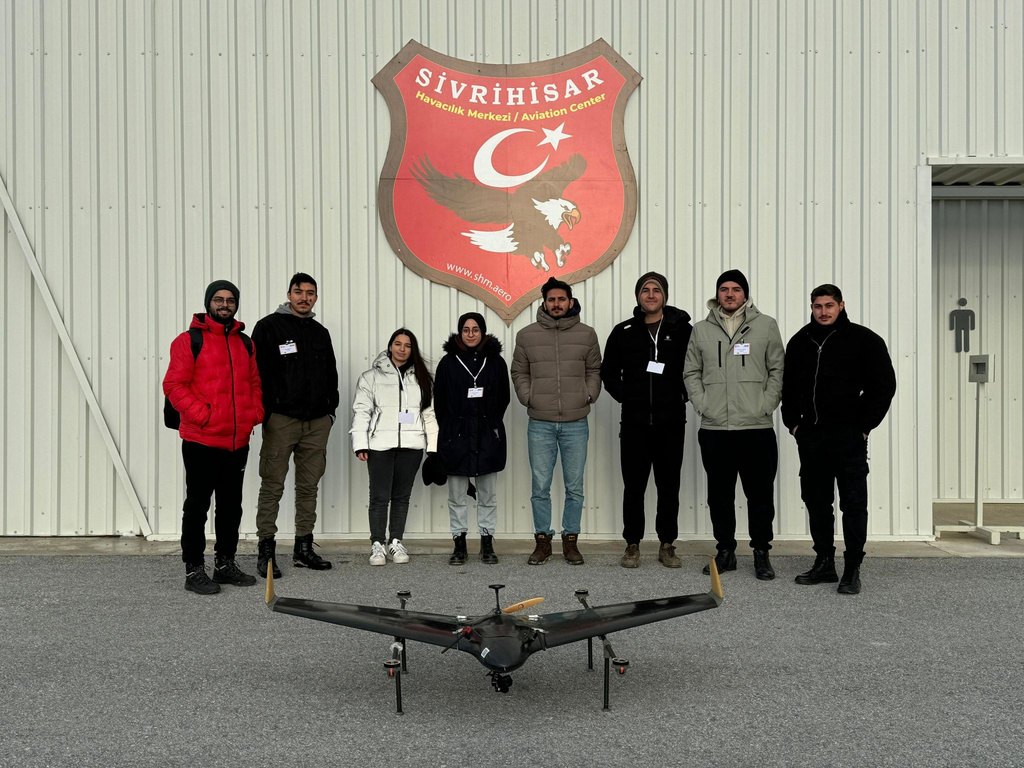
With the Girift UAV team I was responsible for software on the fixed-wing payload-carrying UAV that reached the TEKNOFEST 2024 finals.
Technical Approach
- Mission algorithm design and a custom YOLOv8-based target detection model.
- Python and C# software configured to work with the electronics for reliable autonomous missions.
Key Features
- Vehicle control over MAVLink
- Software integration of embedded hatch open/close and payload-release mechanisms
Results & Achievements
Finalist
TEKNOFEST 2024 International UAV Competition
Gallery
05 / Contact
Let’s build something intelligent.
Interested in autonomous systems, software or ambitious engineering projects? I’d love to hear from you.