Back to Projects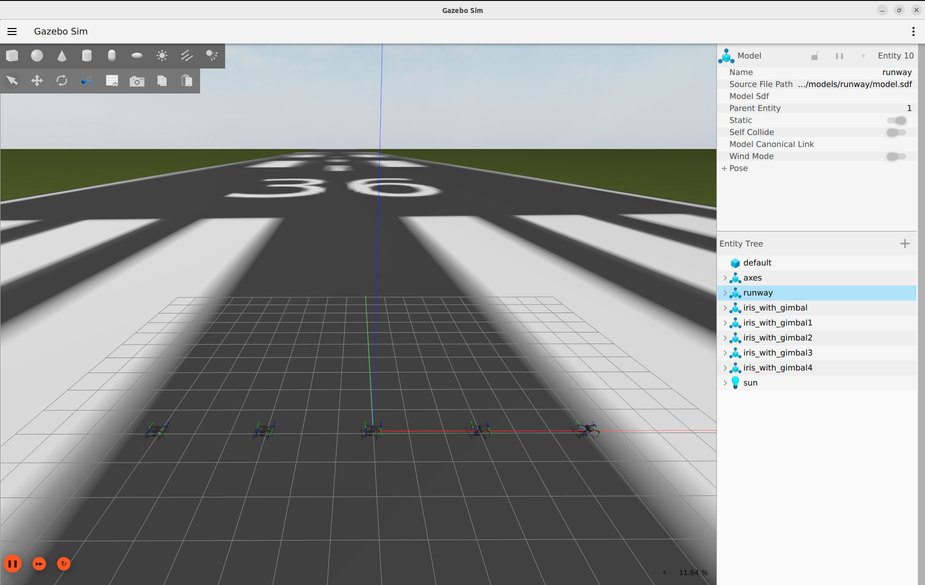
Graduation Project · Autonomous Systems · 2025
P.A.R.S. Autonomous Multi-UAV Surveillance System
Overview
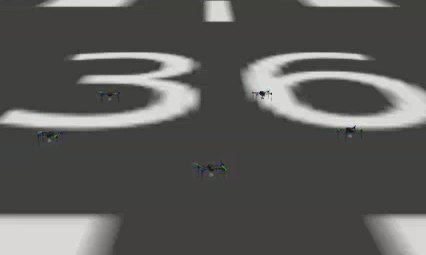
For my graduation project I built a swarm UAV surveillance system controlling multiple UAVs through mobile and desktop applications, set up a Gazebo and ArduPilot simulation environment and handled real-time data and mission planning over MAVLink.
Technical Approach
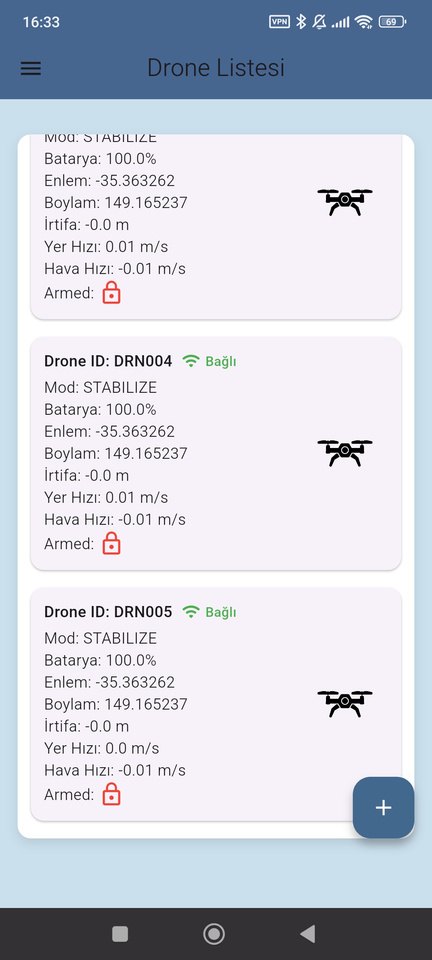
- Mobile GCS: UAV data received securely over a virtual private network (VPN/VPC) using TCP sockets.
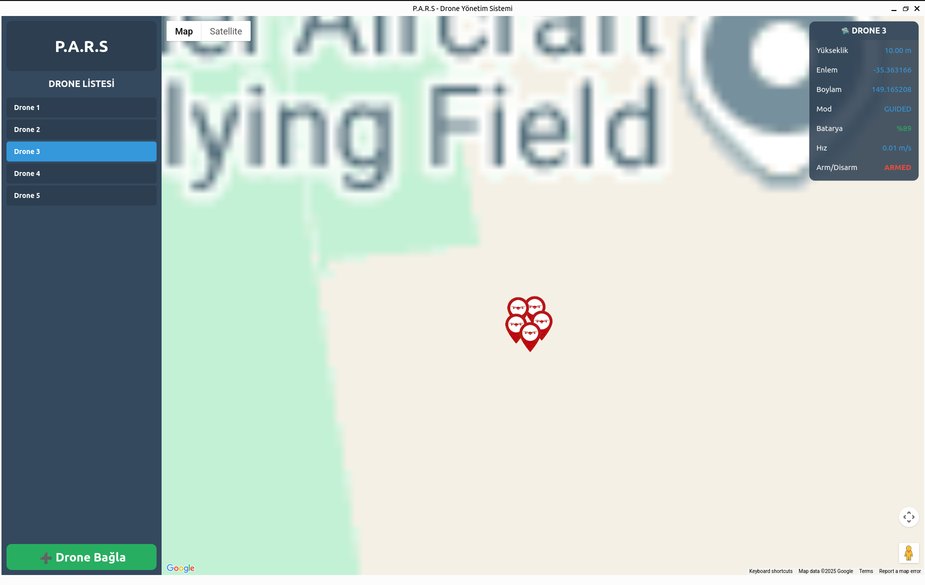
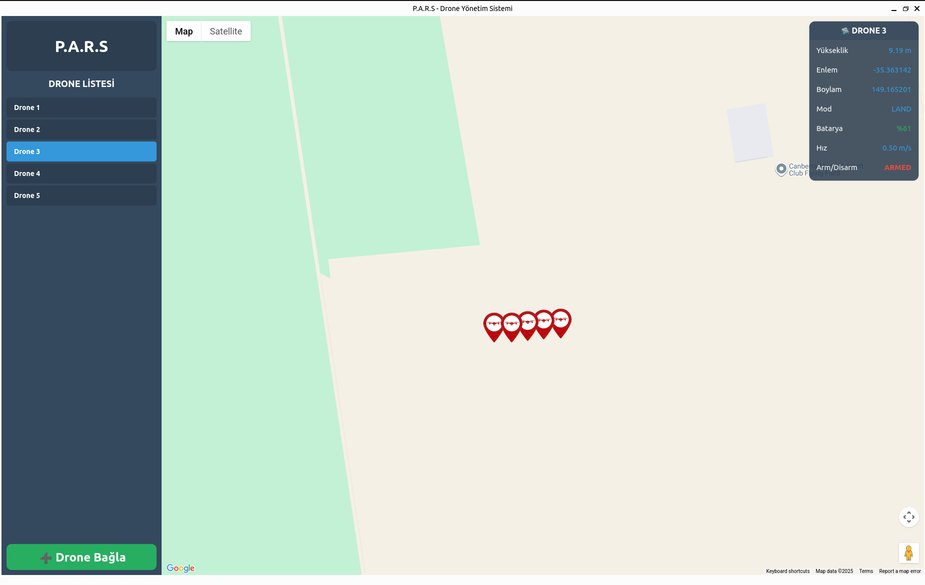
- Desktop GCS: low-latency C++ / Qt interface; telemetry via MAVSDK with multi-connection support to manage the whole swarm from one interface.
- Algorithms and UI simulated and tested in Gazebo and ArduPilot SITL.
Key Features
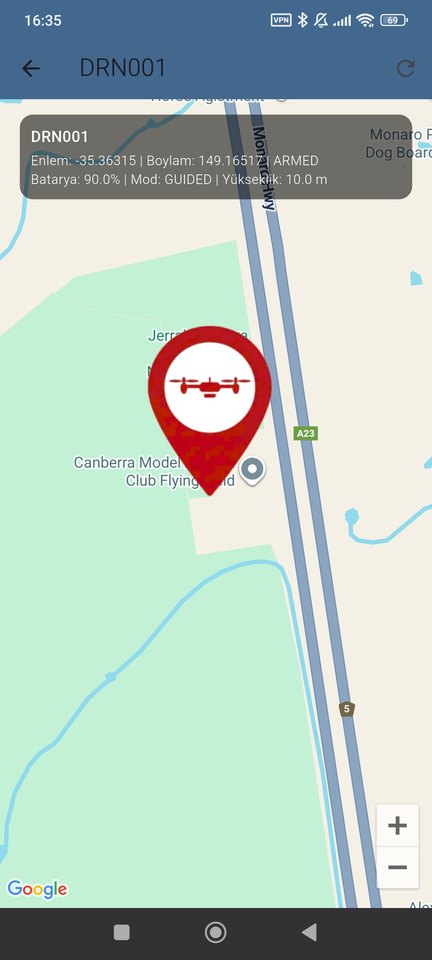
- Multi-UAV monitoring and real-time telemetry (battery, GPS position, speed, altitude)
- Dynamic position tracking with map integration (Google Maps)
- Live visualization of swarm formation and each UAV's status
- TCP socket communication and MAVLink
- Multi-UAV coordination
System Architecture
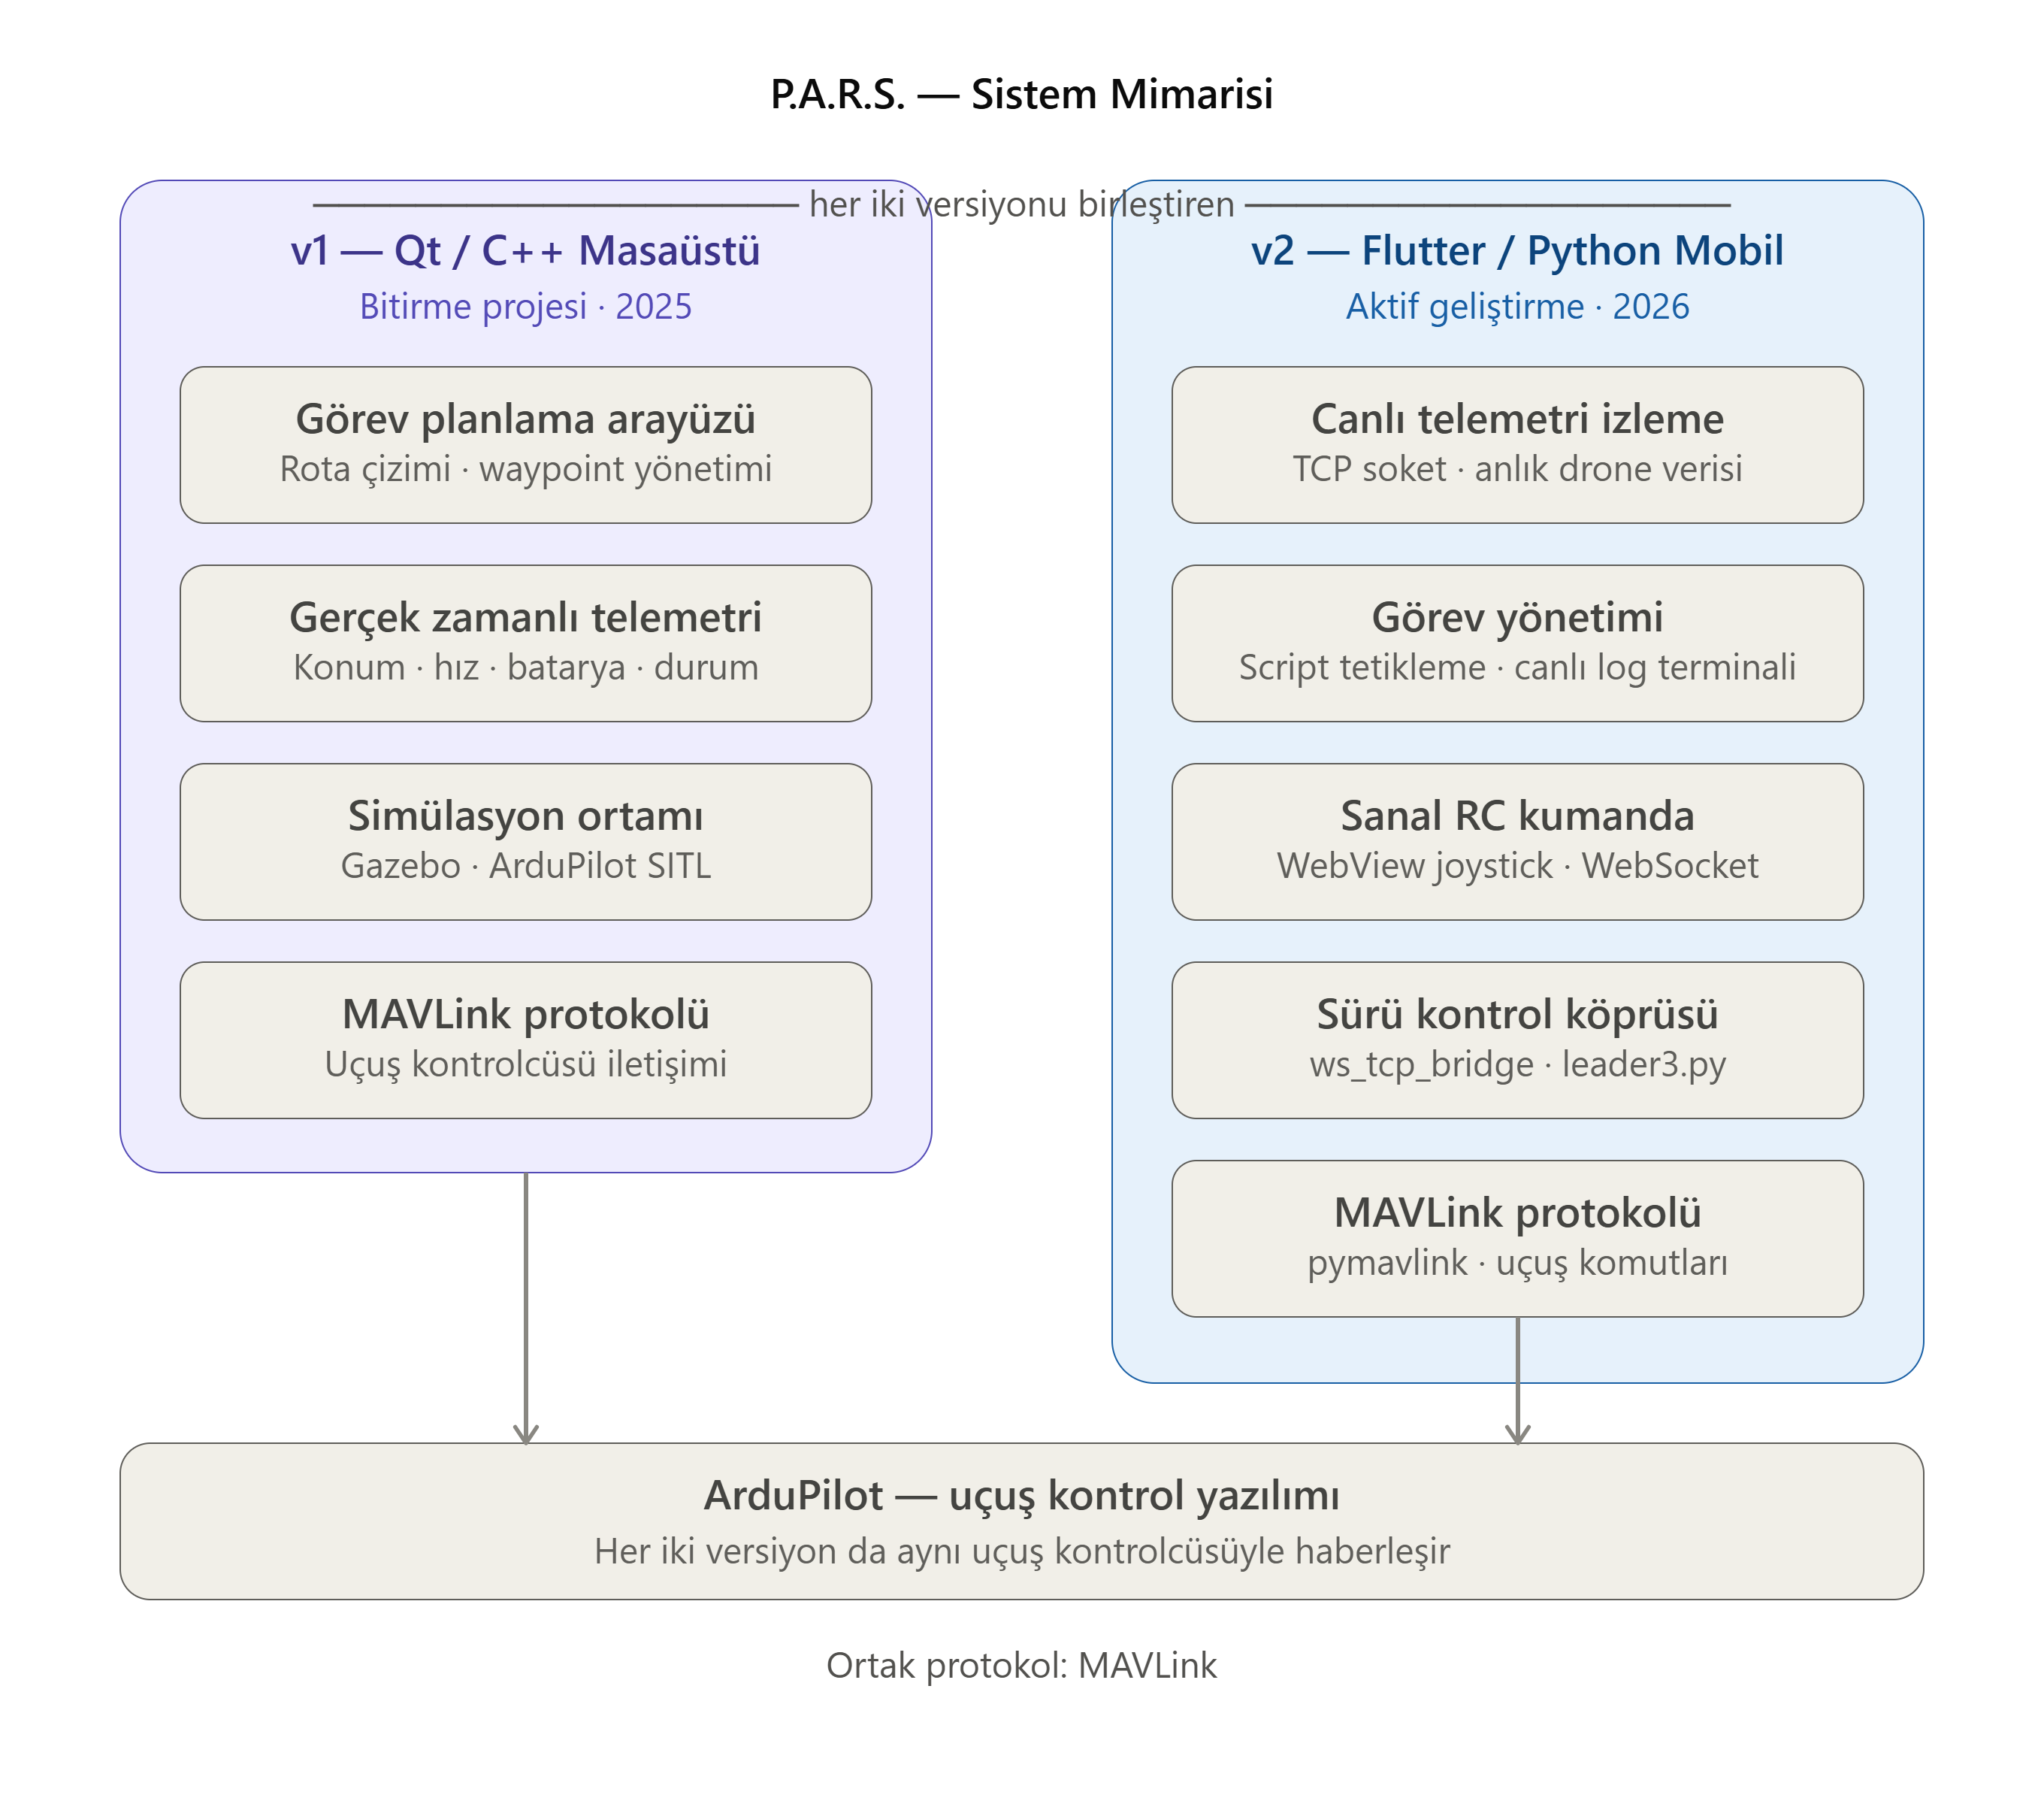
Mobile GCS
Flutter (Android)Google Maps APINetwork security
Network
TCP SocketVPN / VPC
Desktop GCS
C++ / QtMAVSDKMulti-connection
Simulation
GazeboArduPilot SITLROS
Gallery
05 / Contact
Let’s build something intelligent.
Interested in autonomous systems, software or ambitious engineering projects? I’d love to hear from you.