Overview
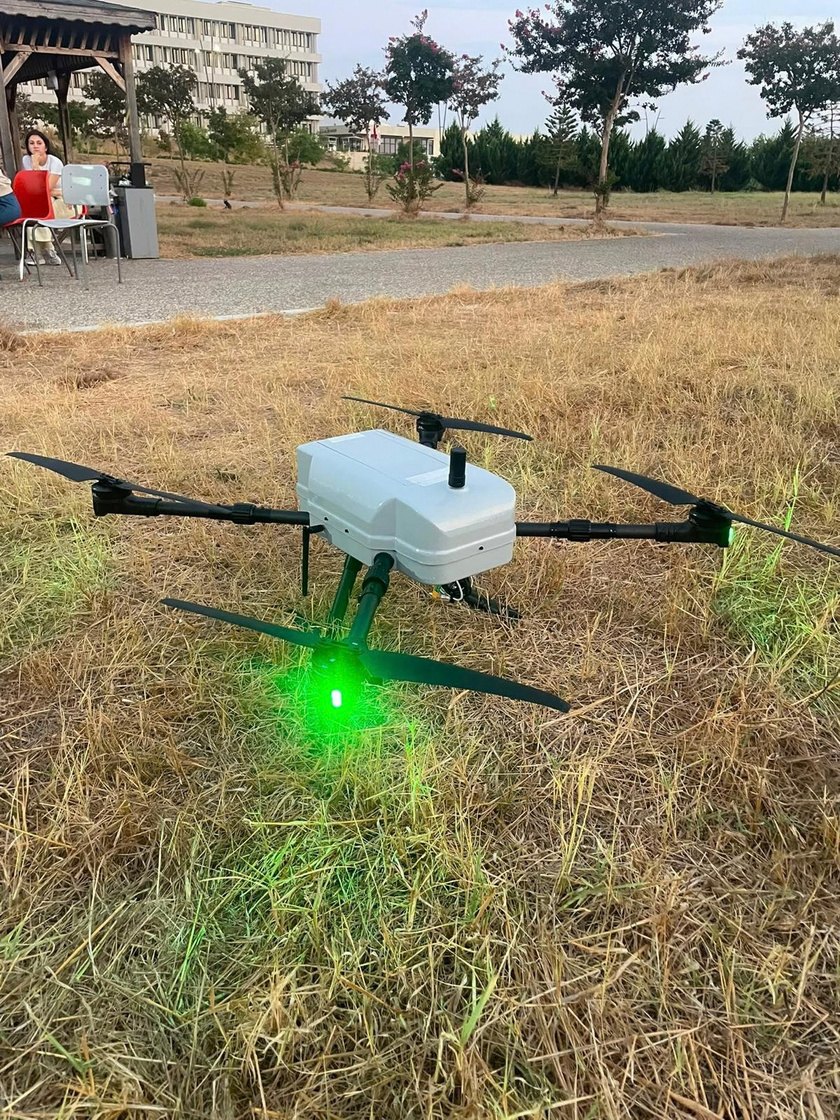
I developed UAV software systems for the SUAS 2026 (USA) finalist GIRIFT UAV team: autonomous target detection, target position estimation and payload release.
Technical Approach
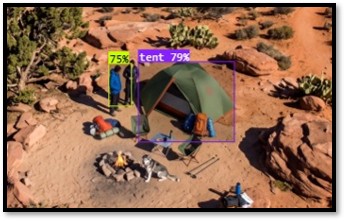
- AI-based target detection from camera images; the target's geographic position computed from GPS, altitude and camera data.
- MAVLink link between Jetson and Pixhawk integrating image processing, mission algorithms and flight control.
Key Features
- Autonomous target detection
- Geographic target position estimation: GPS + altitude + camera geometry
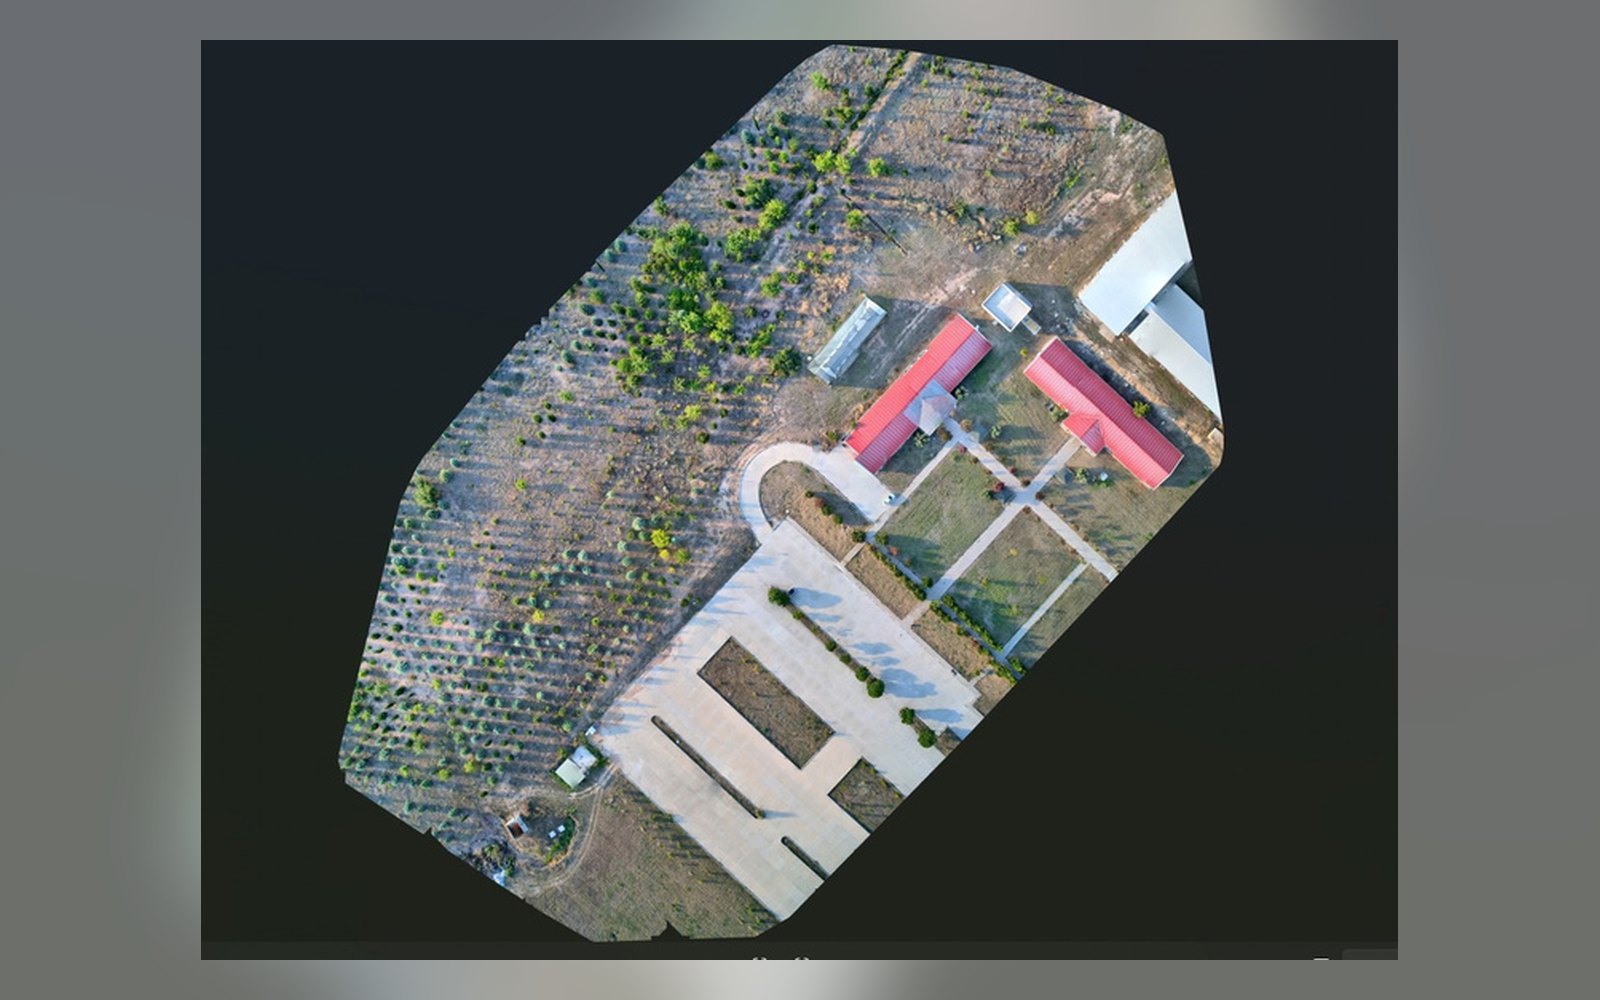
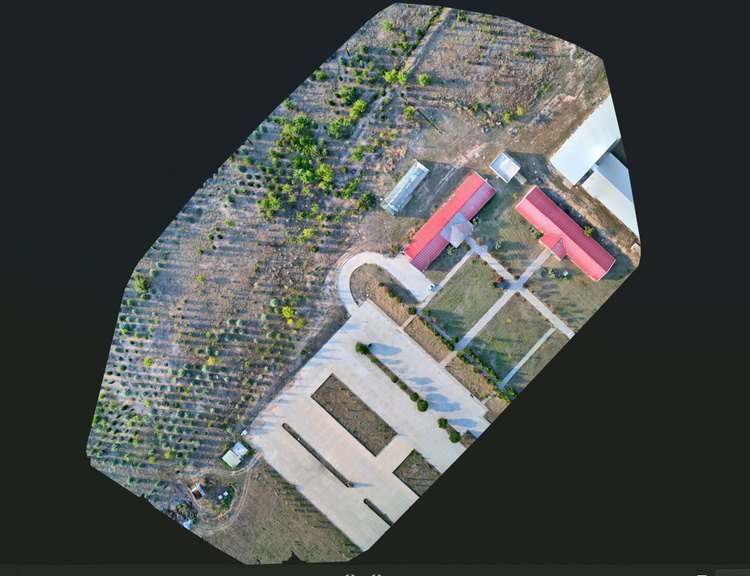
- Orthomosaic mapping from aerial photos captured in flight
- Autonomous approach to detected targets
- Software-controlled payload release mechanism
System Architecture
Perception
YOLOOpenCVTarget detection
Estimation
GPS + altitudeCamera geometry
Onboard compute
JetsonOrthomosaic mapping
Flight controller
PixhawkMAVLinkPayload release
Results & Achievements
Finalist
SUAS 2026 (USA)
Gallery

05 / Contact
Let’s build something intelligent.
Interested in autonomous systems, software or ambitious engineering projects? I’d love to hear from you.