Overview
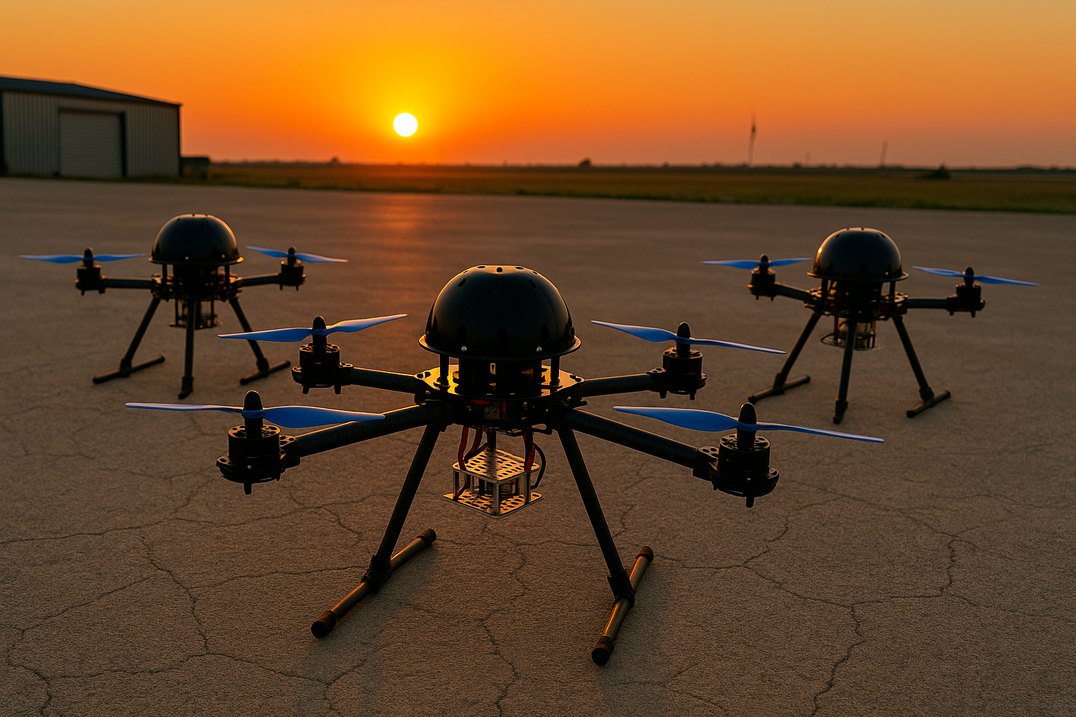
With PULSAR UAV I developed an ArduPilot-based multi-UAV control system for the TEKNOFEST 2025 Swarm UAV Competition.
Technical Approach
- Simultaneous mission planning algorithms and AI-assisted target detection integrated.
- Custom protocols for secure, low-latency inter-vehicle communication.
- All missions tested and verified in the Gazebo simulation environment.
Key Features
- Coordinated autonomous movement with a leader–follower model
- Formation flight and target discovery
- Dynamic add/remove of UAVs in the swarm
Results & Achievements
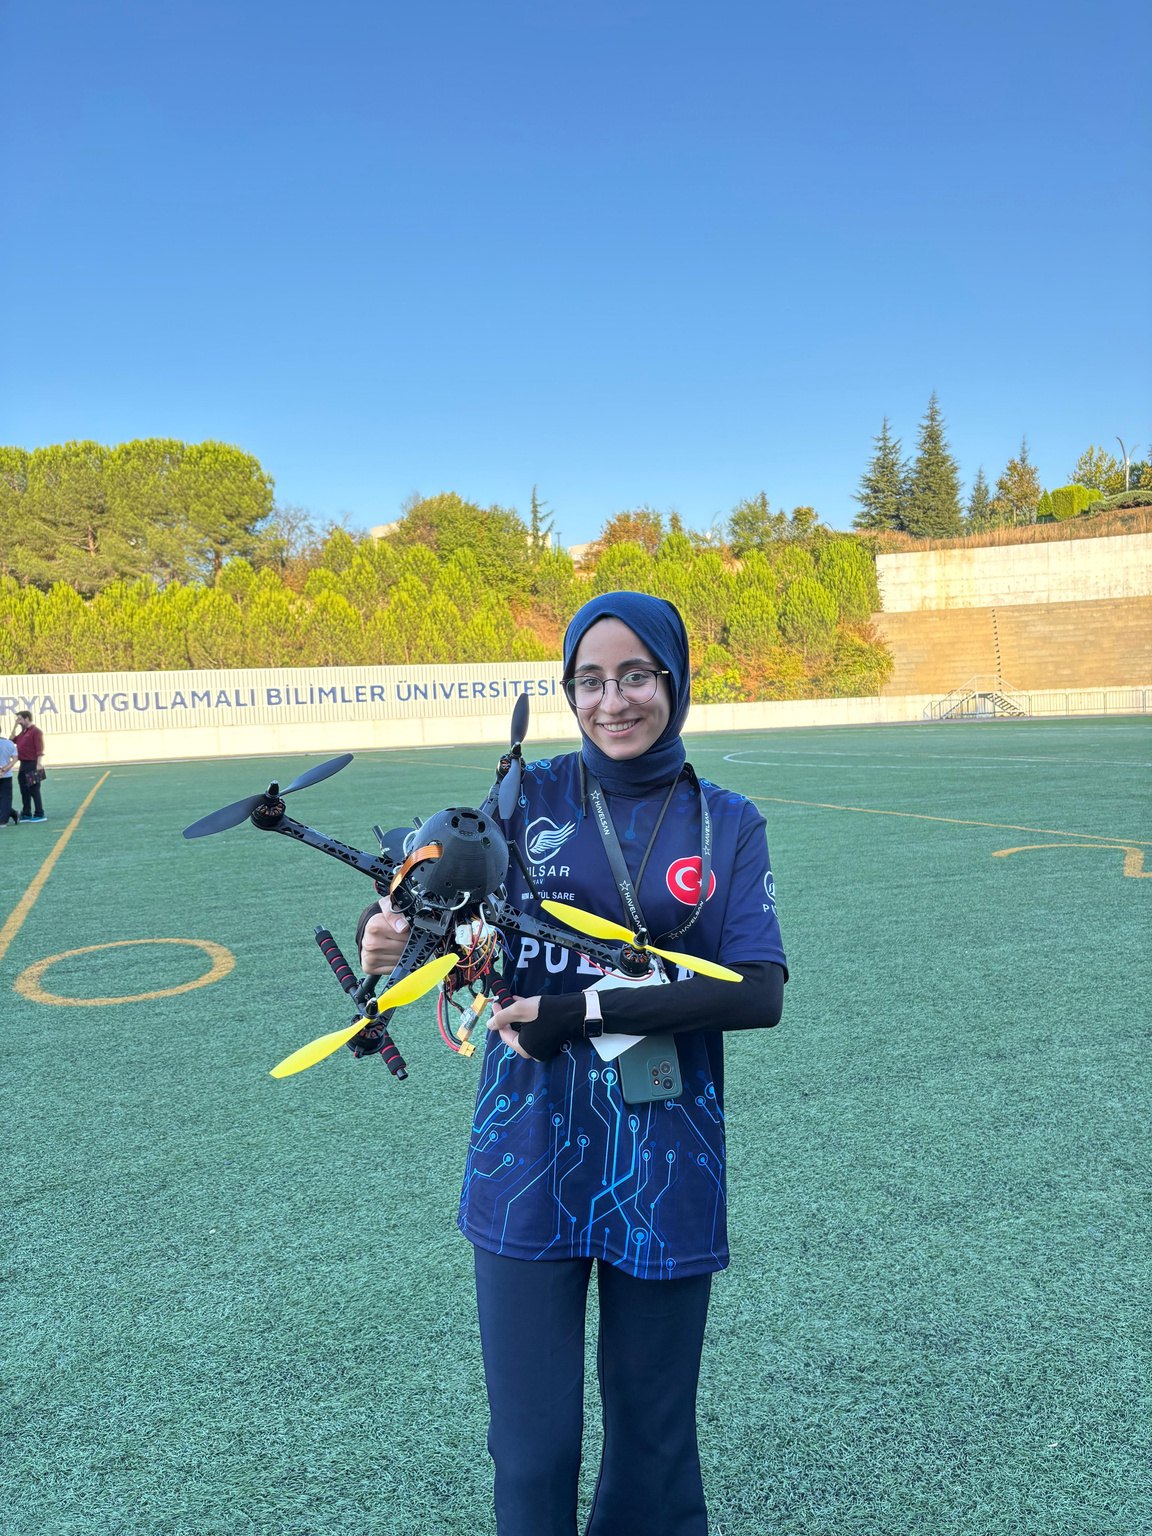
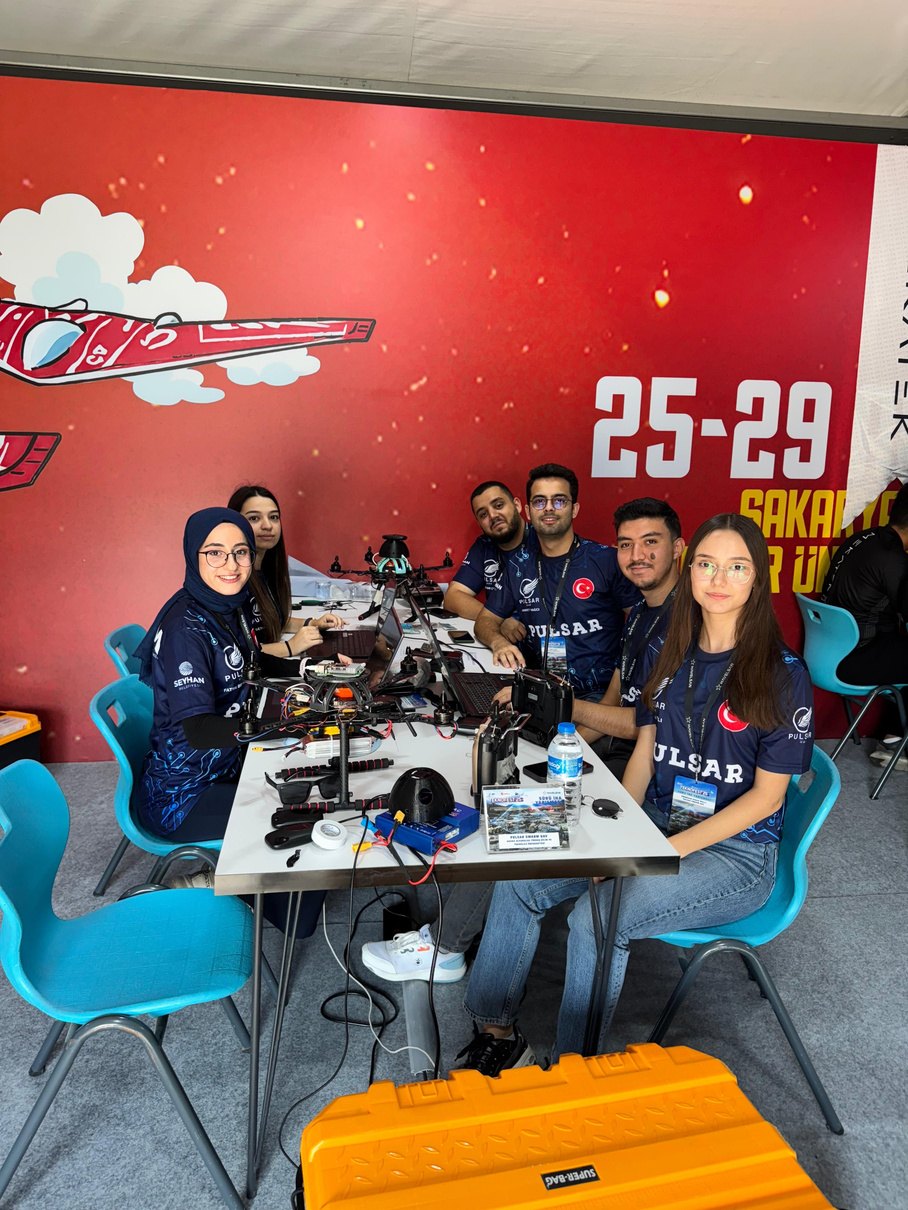
Finalist
TEKNOFEST 2025 Swarm UAV Competition
Gallery
05 / Contact
Let’s build something intelligent.
Interested in autonomous systems, software or ambitious engineering projects? I’d love to hear from you.